Lab 03: SRV02 Position Control
AE 443 · Experimental Dynamics and Control Laboratory · Spring 2026 · ERAU
Experiment Overview
Position control is fundamental to flight control actuators, robotic arms, gimbal systems, and telescope pointing mechanisms. The challenge is achieving a fast, accurate step response while also tracking continuously-changing reference inputs (like a ramp command) without accumulating position error. This lab designed and implemented a PV controller meeting second-order transient specifications, then demonstrated why adding an integral term is necessary to eliminate the persistent error that appears when the system must track a ramp reference.
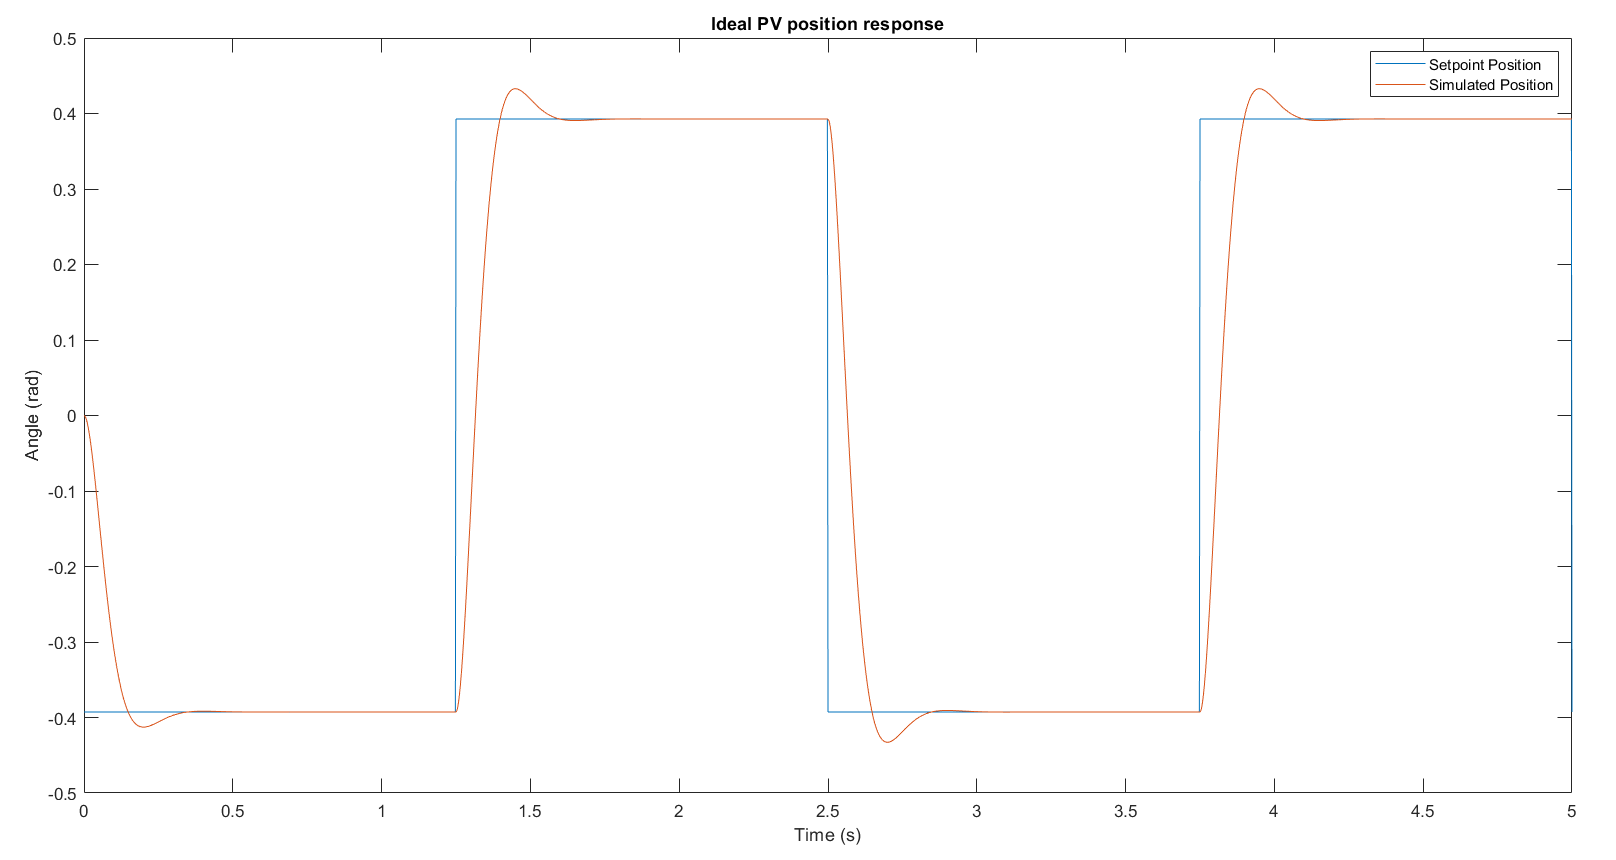
- Design PV (proportional-velocity) controller gains from second-order transient specifications: peak time tp = 0.20 s and percent overshoot PO = 5%
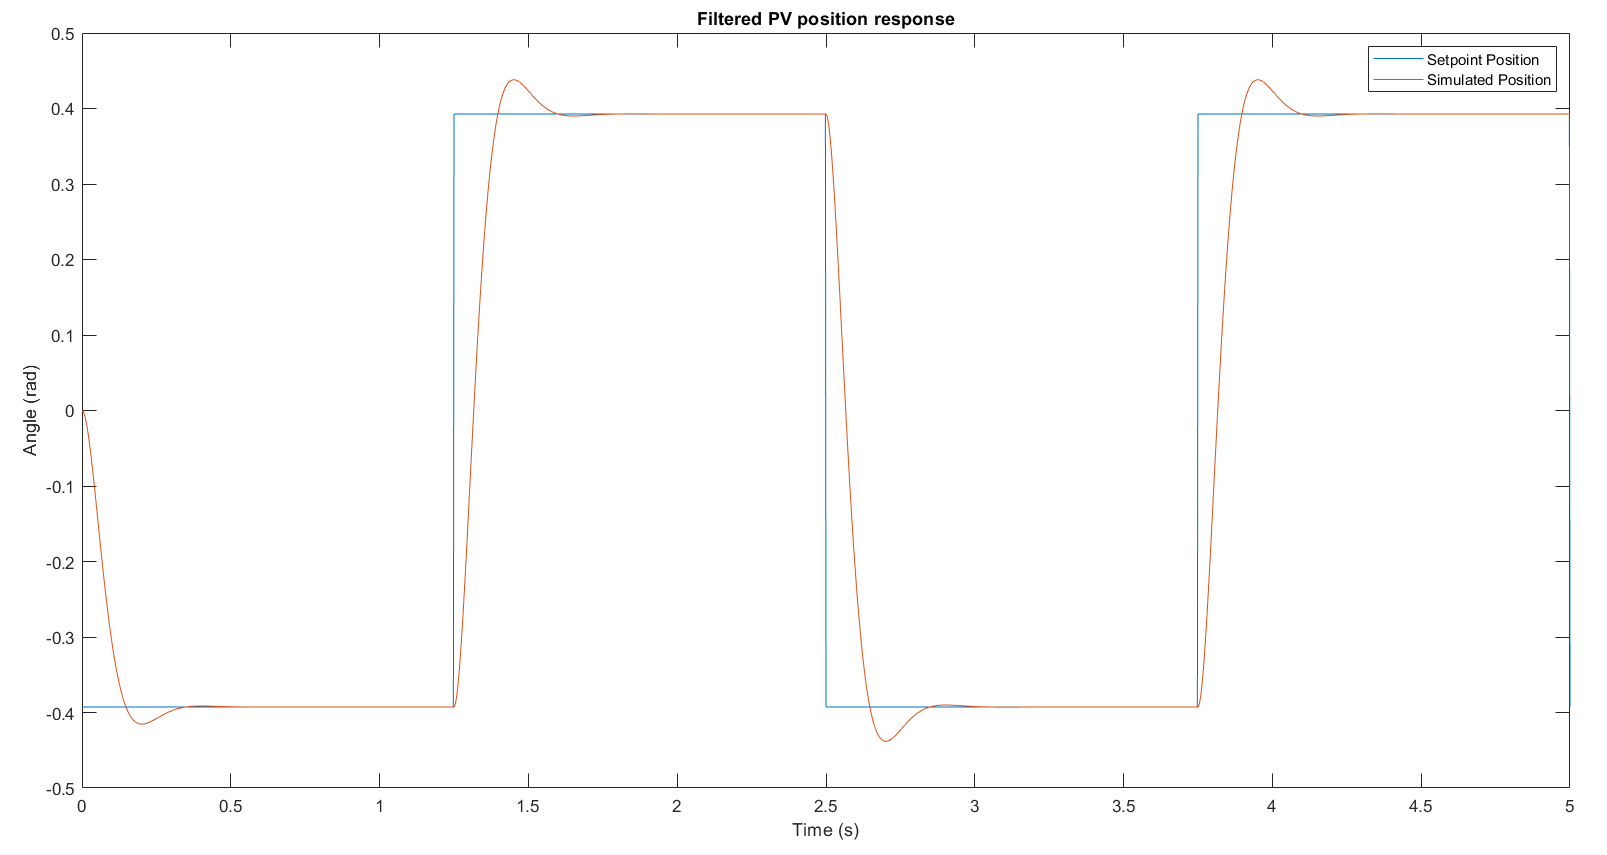
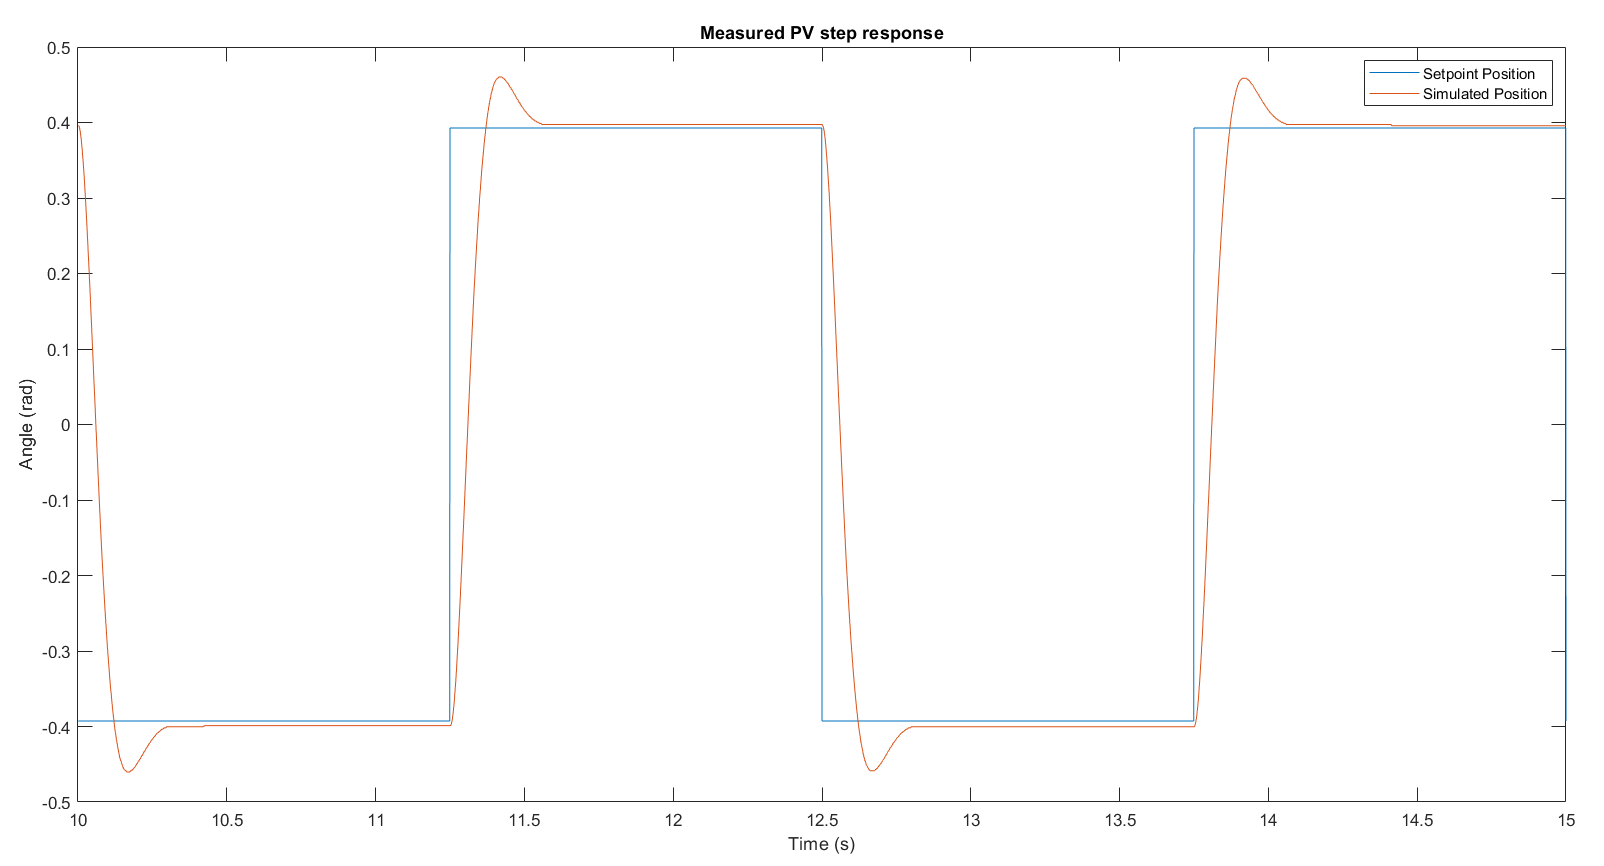
- Validate the step response in simulation and on the physical SRV02 hardware
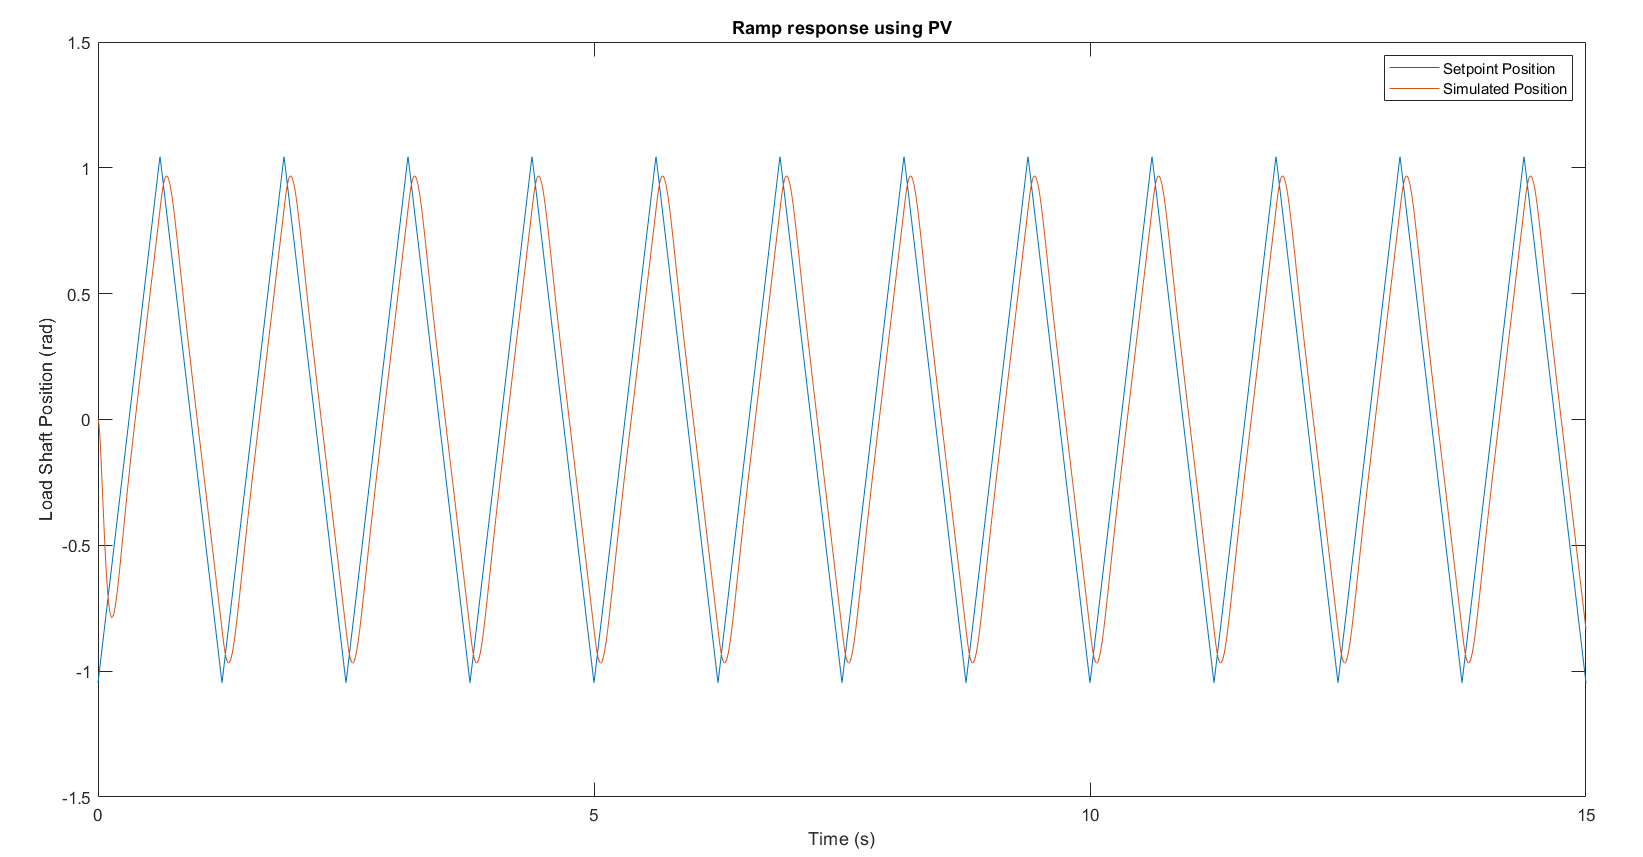
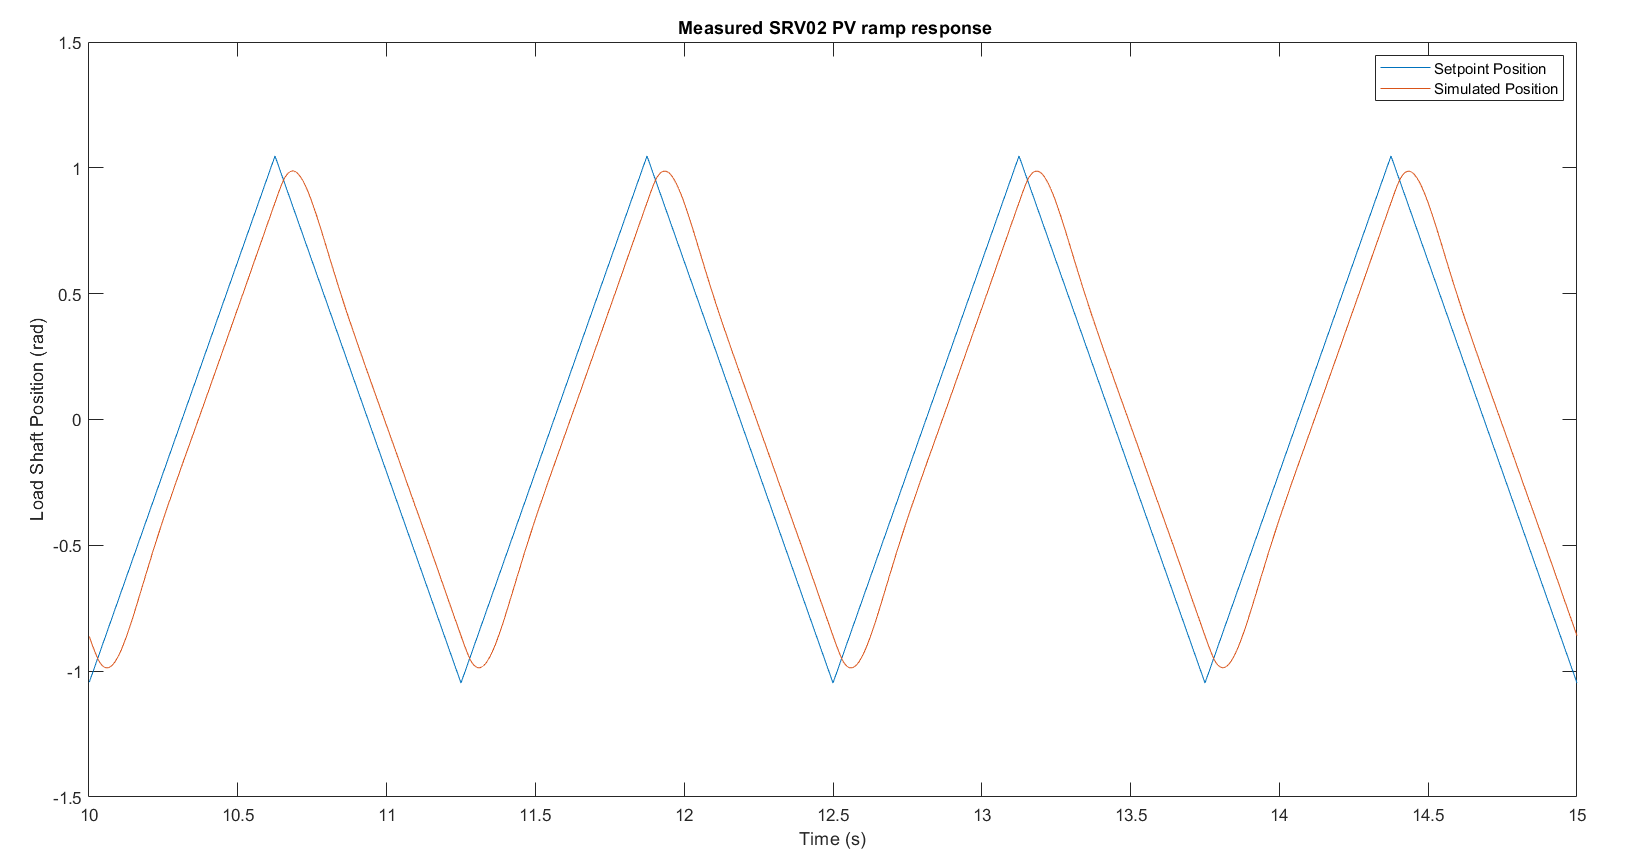
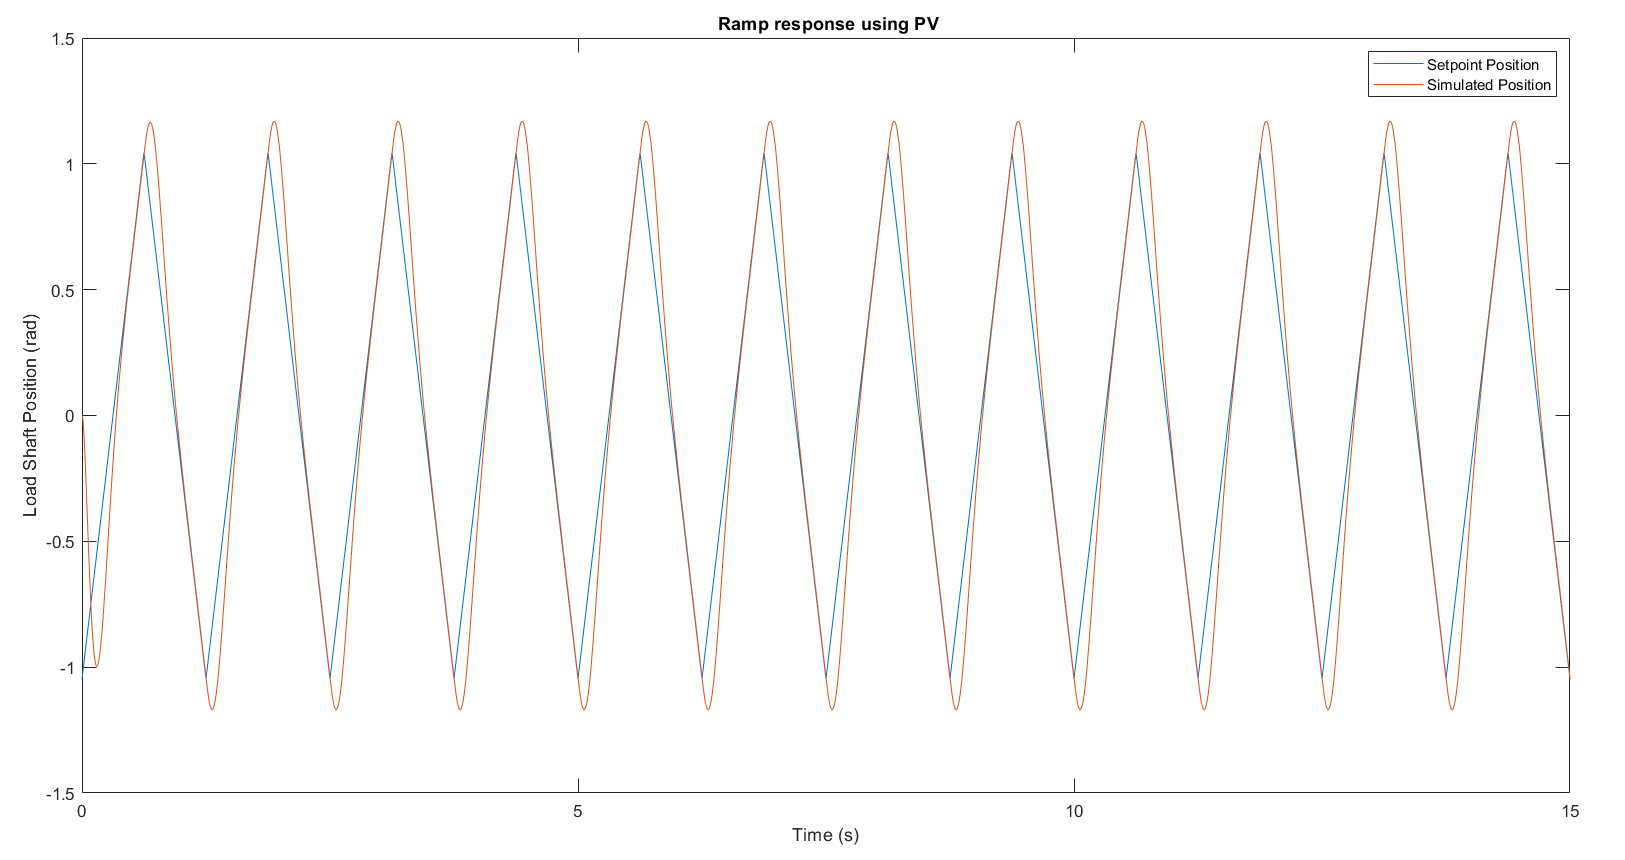
- Demonstrate the ramp tracking steady-state error inherent to PV-only control
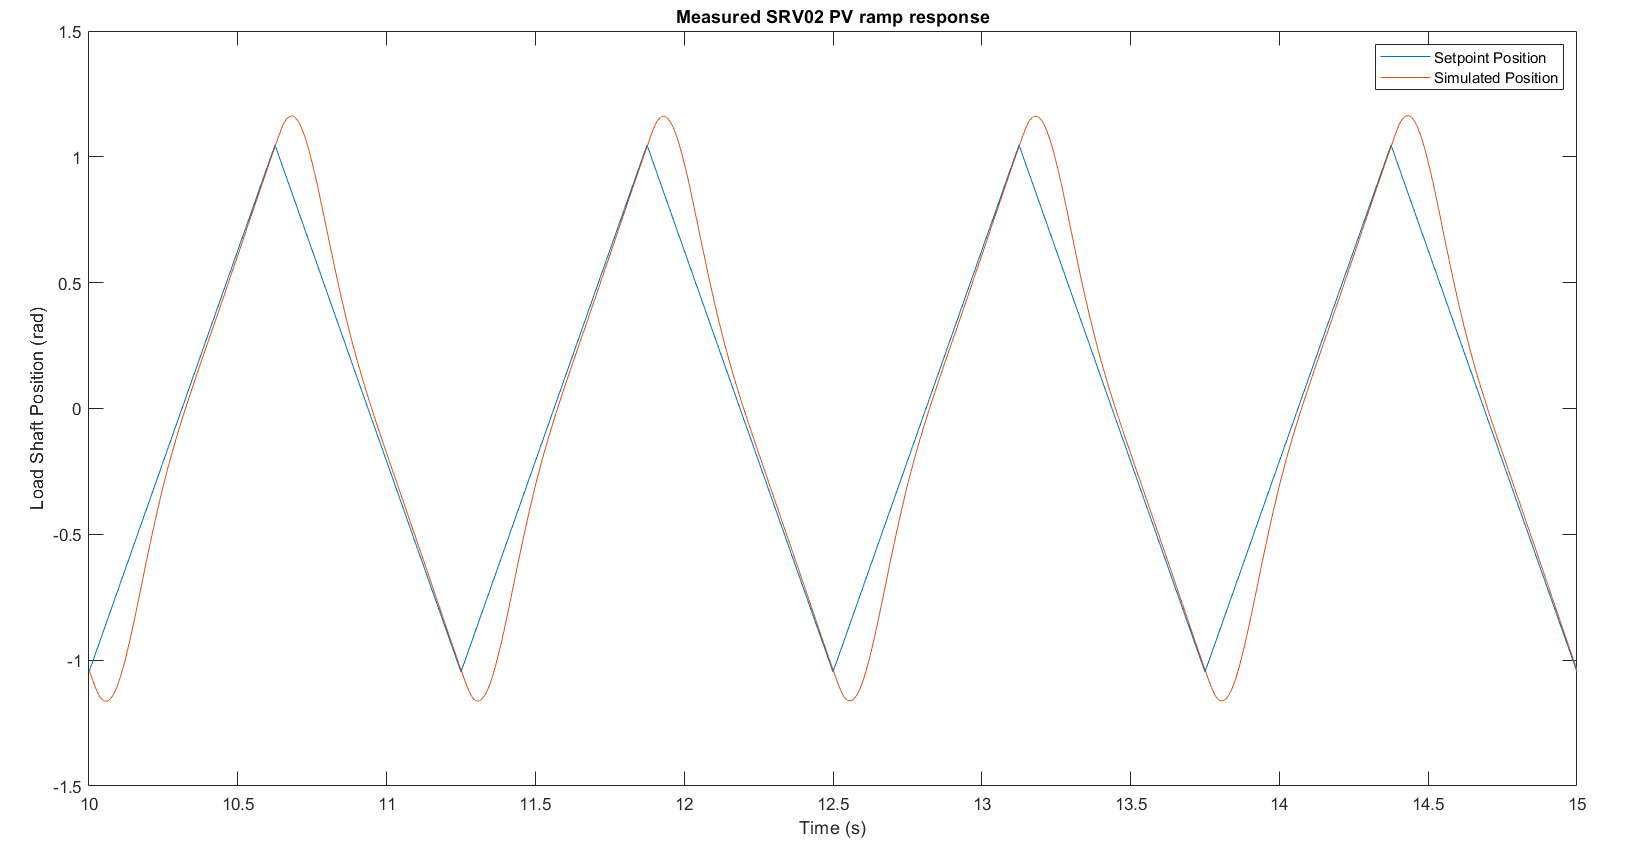
- Add an integral gain to create a PIV controller and reduce ramp steady-state error to near zero
Equipment & Tools
- Quanser SRV02 rotary servo-motor system
- Q2-USB data acquisition board
- VoltPAQ power amplifier (Vmax = ±10 V)
- MATLAB/Simulink with QUARC real-time toolbox
- Encoder feedback for position measurement (load shaft optical encoder)
Controller Design
The desired transient specs (tp = 0.20 s, PO = 5%) were mapped to second-order system parameters: ζ = 0.69 and ωn = 21.7 rad/s. The PV gains were then derived analytically:
kp = τωn² / K = 7.82 V/rad
kv = (2ζωnτ − 1) / K = −0.157 V·s/rad
Since a PV controller makes the position loop a Type-1 system, a ramp input produces a predictable non-zero steady-state error ess = R(1 + Kkv) / (Kkp) = 0.214 rad. Adding an integral gain ki = 38.9 V/(rad·s) upgraded the controller to PIV, eliminating this error by continuously accumulating and correcting residual position deviation.
Key Results
| Test | tp (s) | PO (%) | ess (rad) |
|---|---|---|---|
| Step sim (PV) | 0.194 | 5.0 | 0 |
| Step impl (PV) | 0.170 | 7.86 | 0.004 |
| Ramp sim (PV) | — | — | 0.213 |
| Ramp impl (PV) | — | — | 0.186 |
| Ramp sim (PIV) | — | — | 0.005 |
| Ramp impl (PIV) | — | — | 0.007 |
- Hardware step response (PO = 7.86%) slightly exceeded the 5% design spec, attributable to friction and encoder quantization noise not captured in the model.
- PIV reduced ramp ess from ~0.19 rad to ~0.007 rad — a 97% reduction by adding one integral term, directly validating the Type-2 behavior theory predicts.
Valuable Takeaways
- Transient specifications translate directly into controller gains. Mapping peak time and overshoot to ζ and ωn, then to kp and kv, is a reusable workflow for any second-order position control problem, from aircraft actuators to CNC machine tool axes.
- The type number of a control system determines what inputs it can track without error. PV (Type 1) tracks step positions but accumulates ramp error; PIV (Type 2) tracks both — this distinction drives integrator inclusion decisions in autopilot and flight controller design.
- Hardware always differs from simulation. The 7.86% vs 5% overshoot discrepancy came from real-world nonlinearities. Recognizing and explaining this gap — rather than ignoring it — is what separates competent control engineers from those who only work in simulation.
- Developed proficiency in the complete MATLAB/Simulink hardware-in-the-loop workflow, from analytical gain design and simulation validation through hardware implementation and performance characterization.